Overview
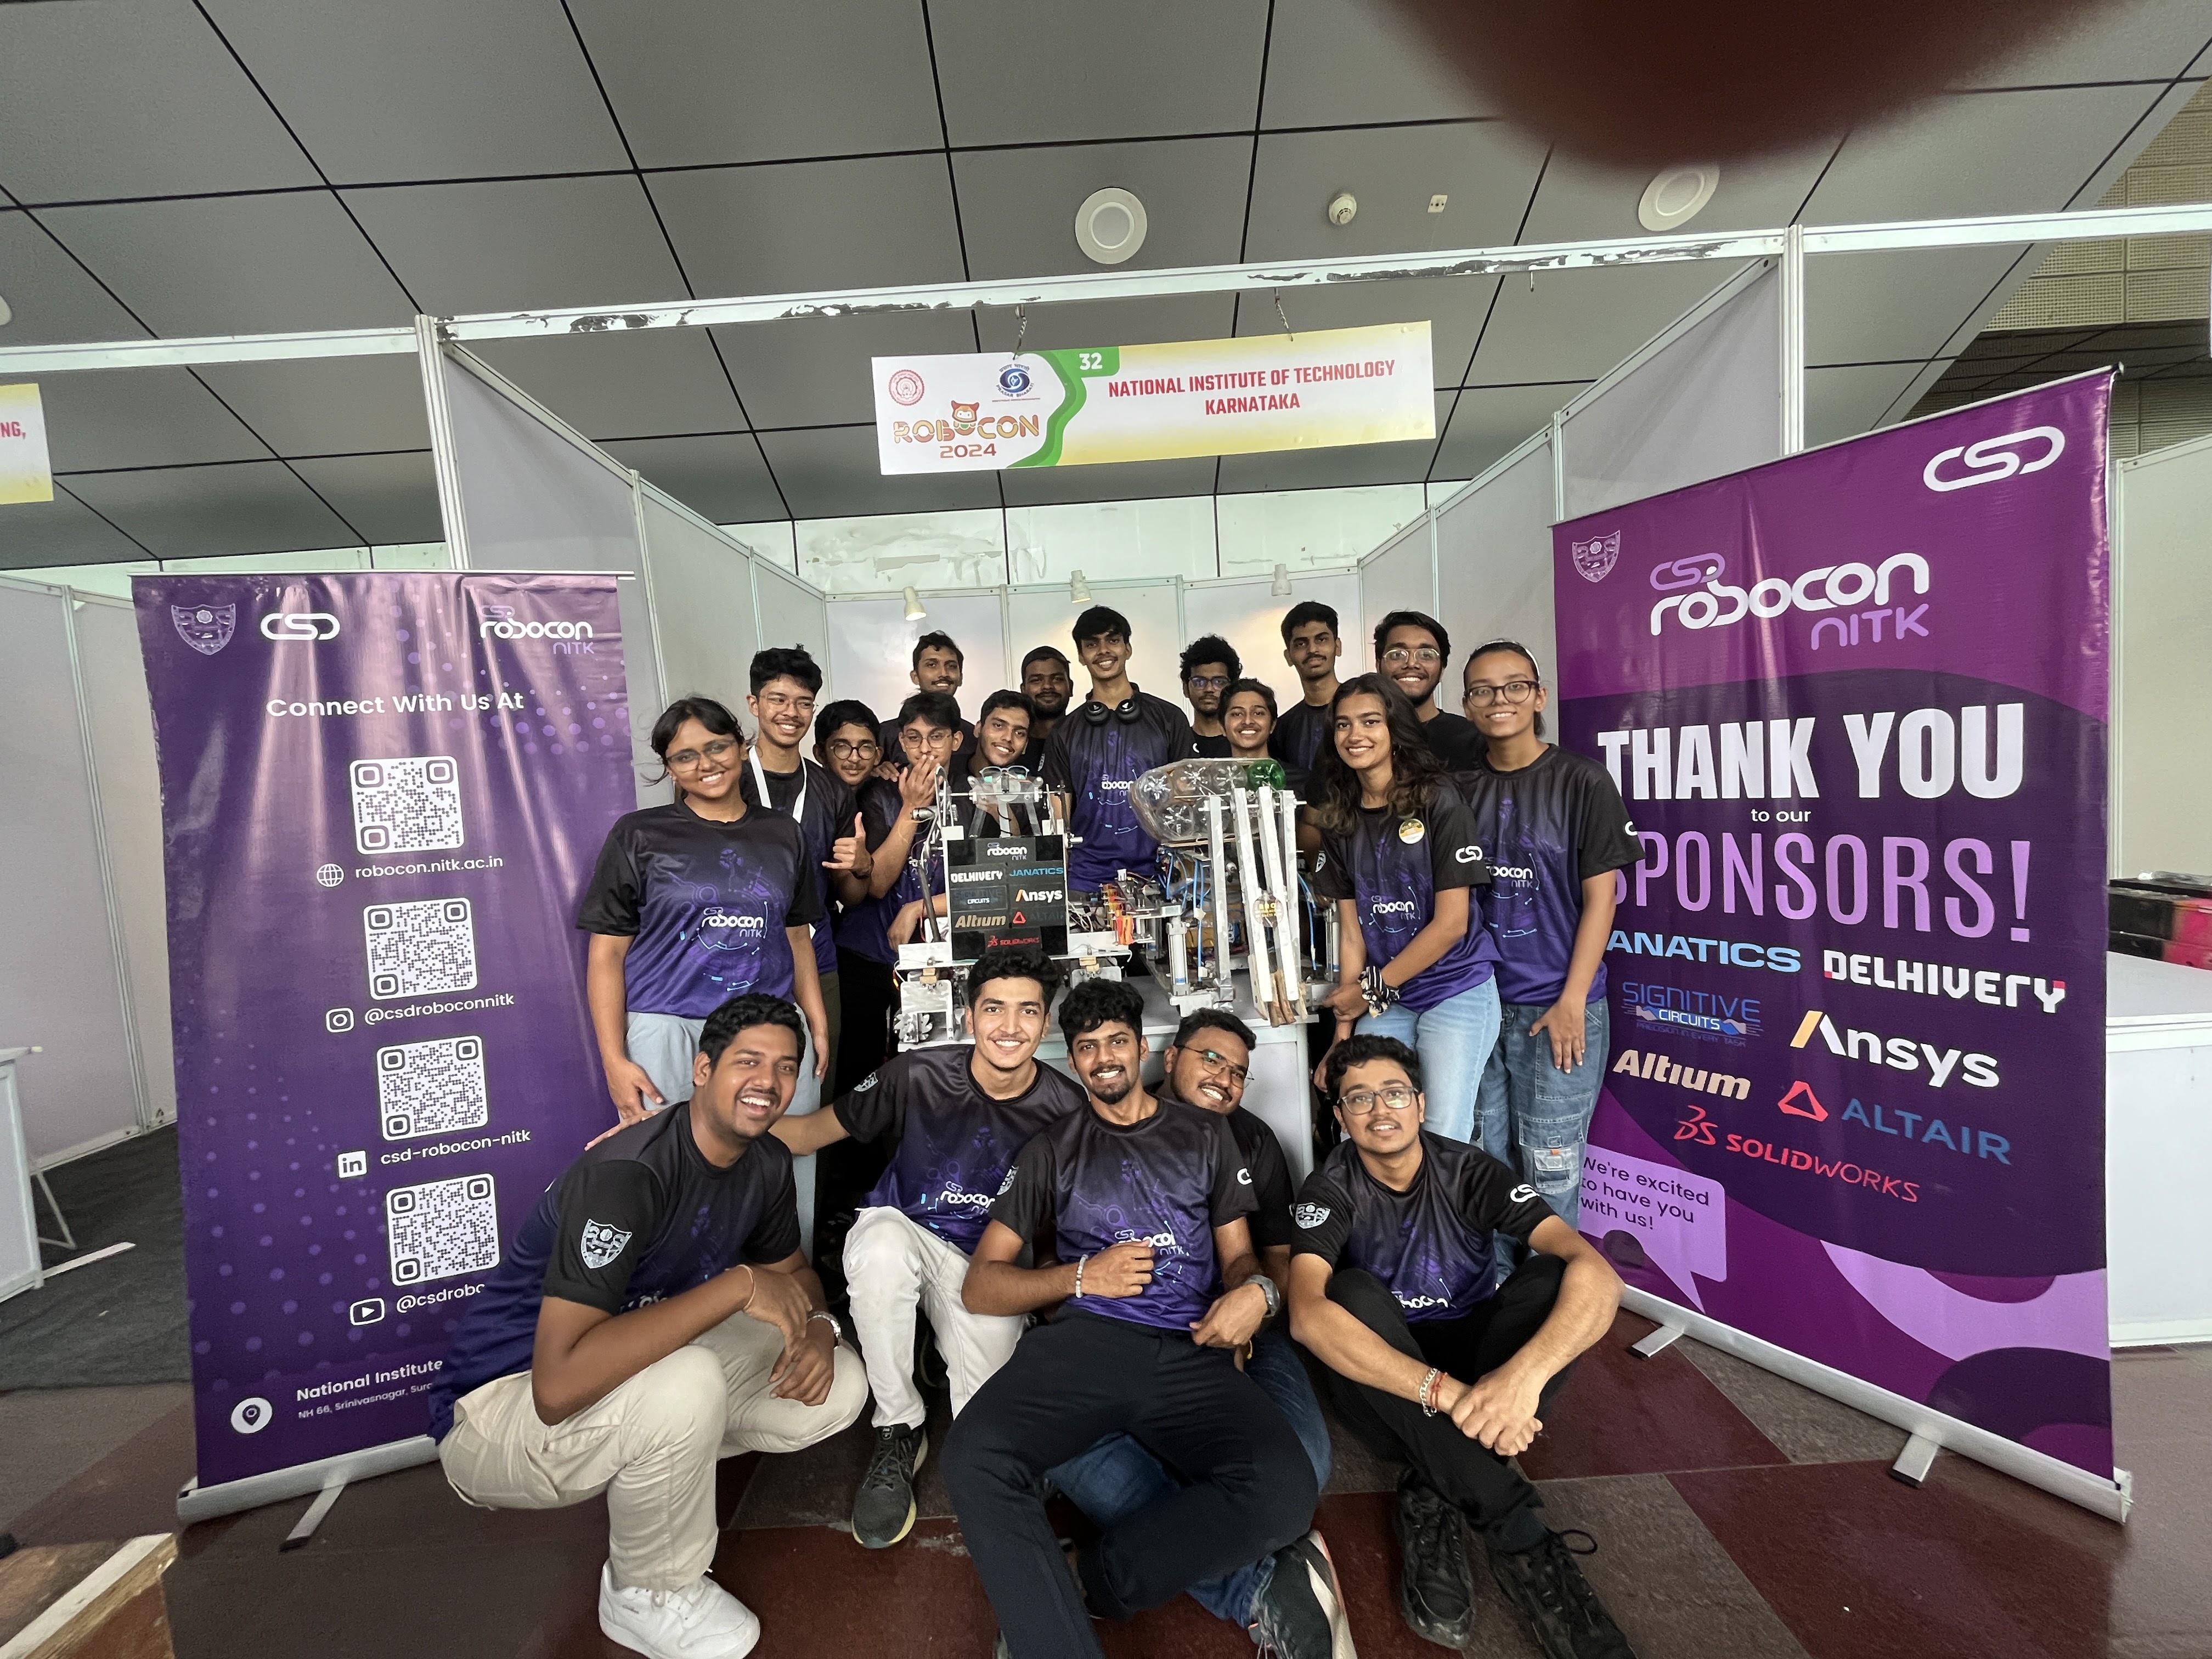
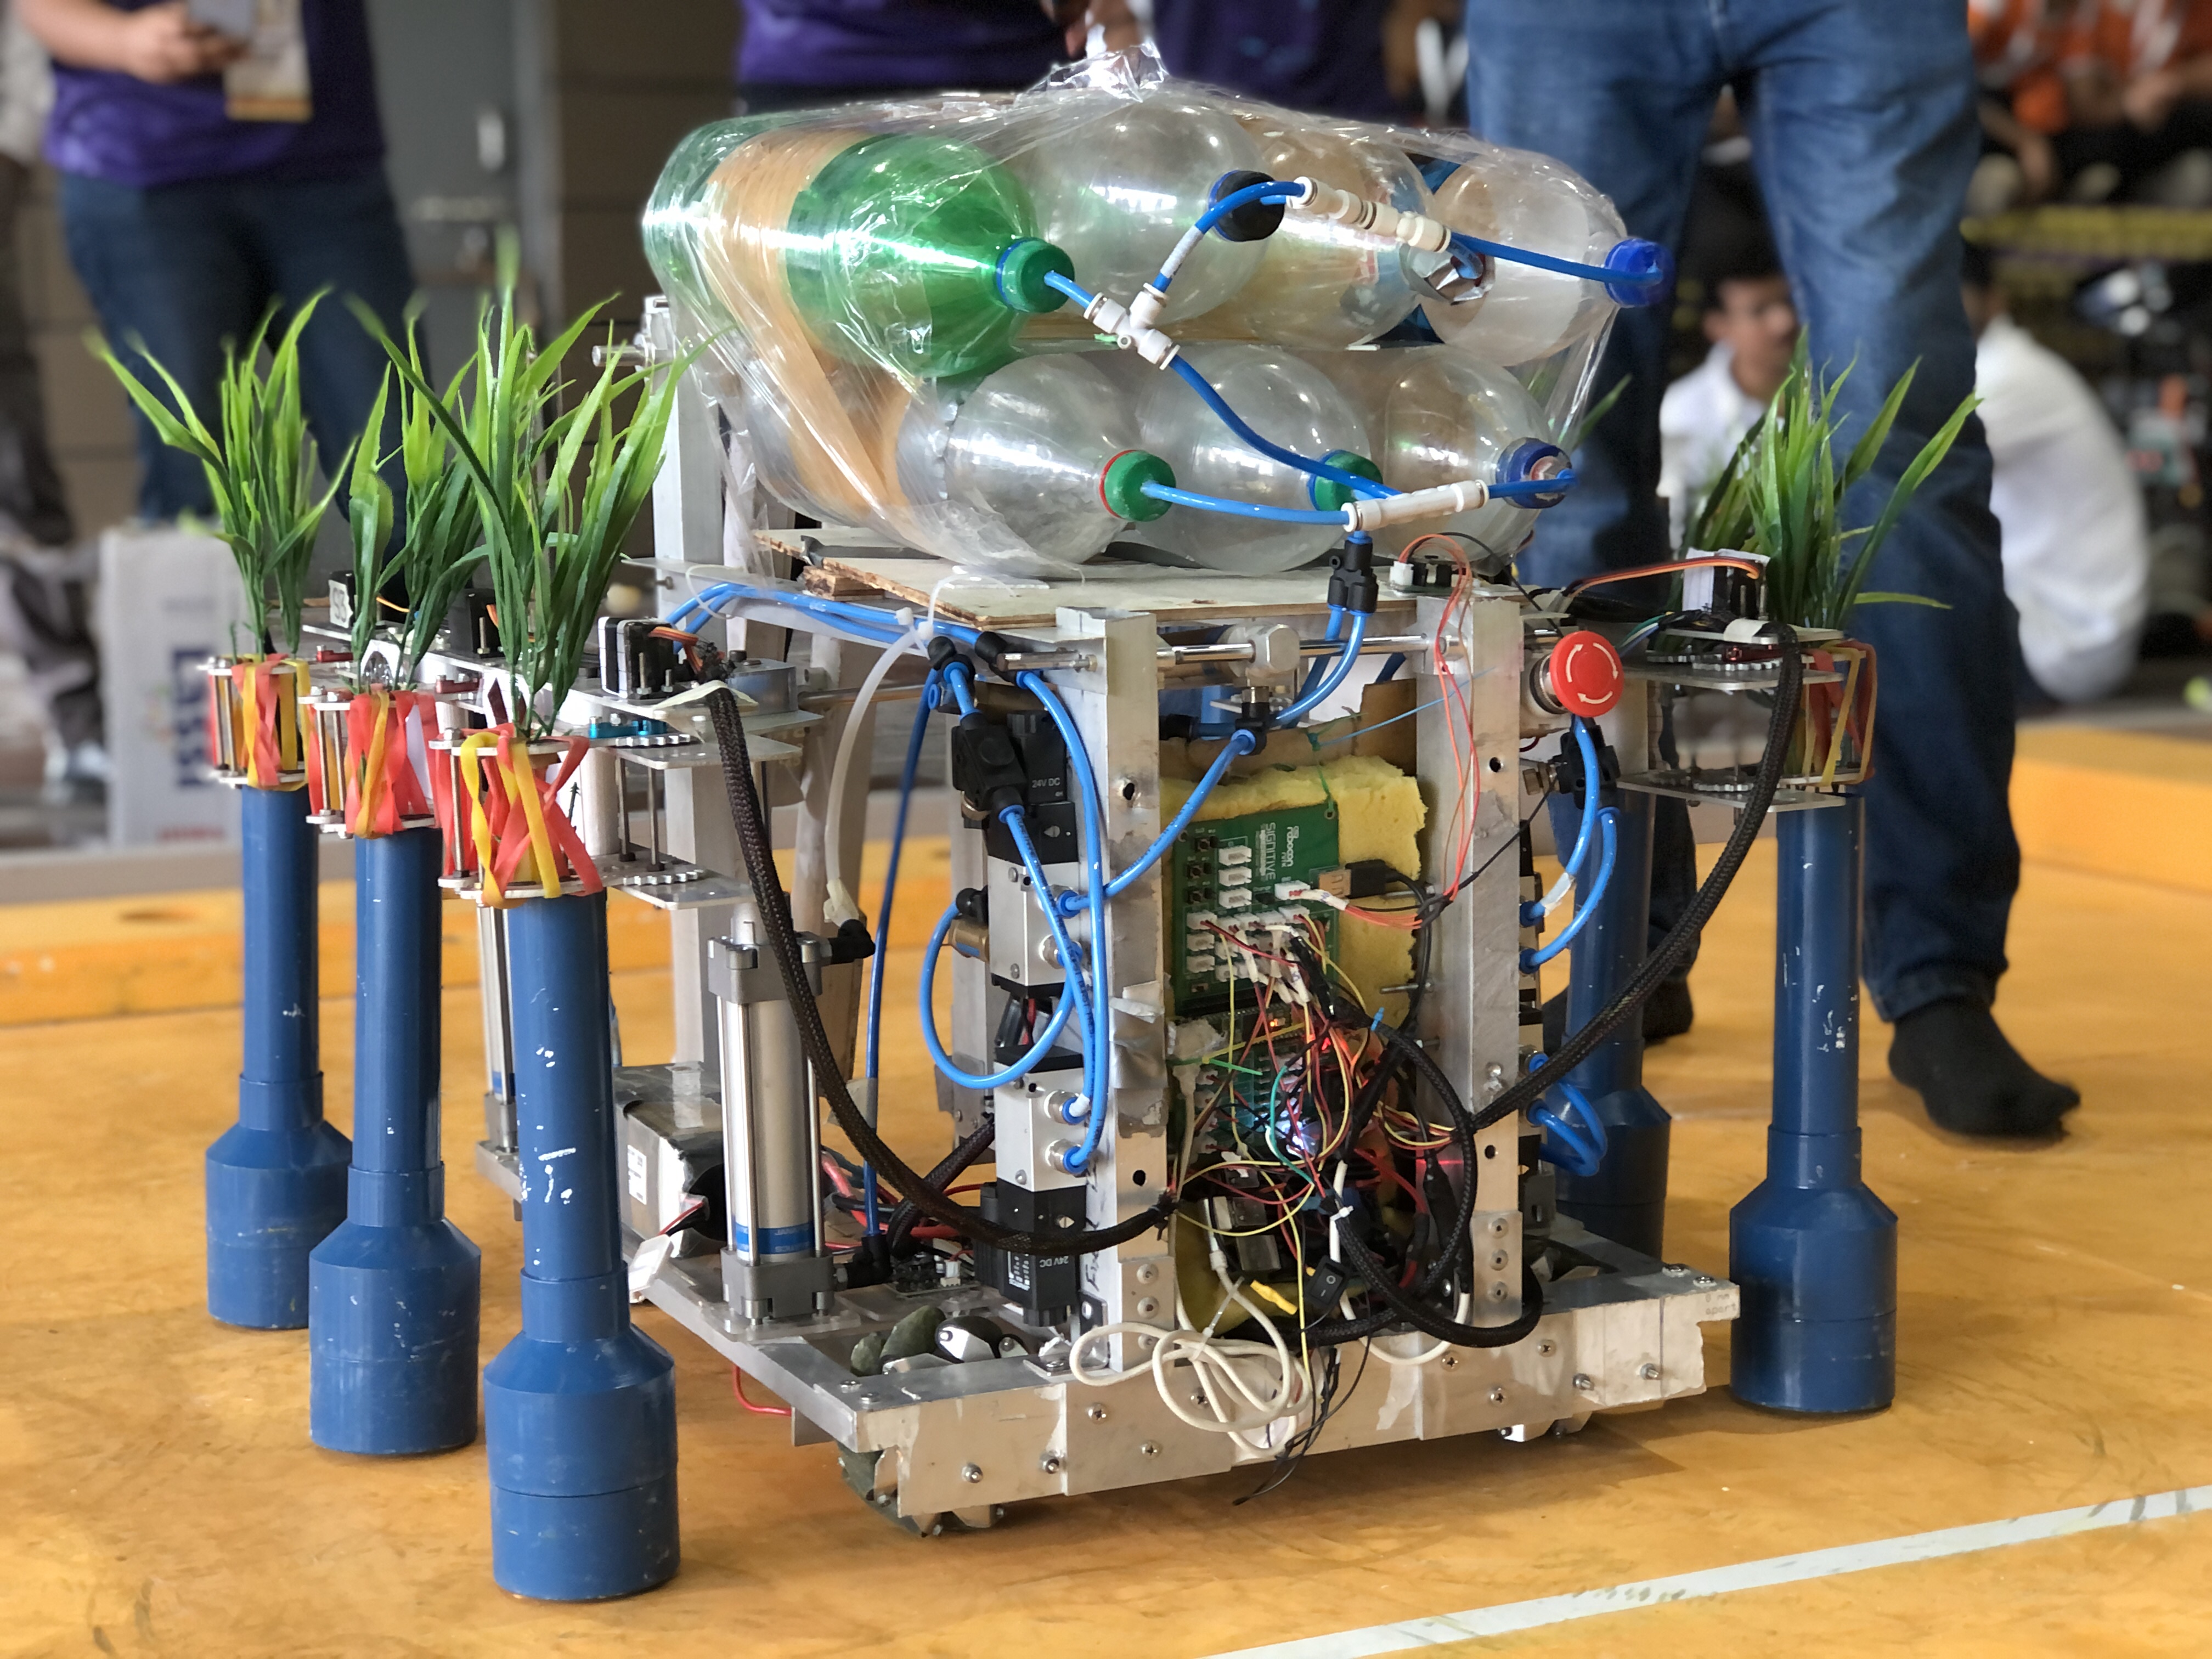
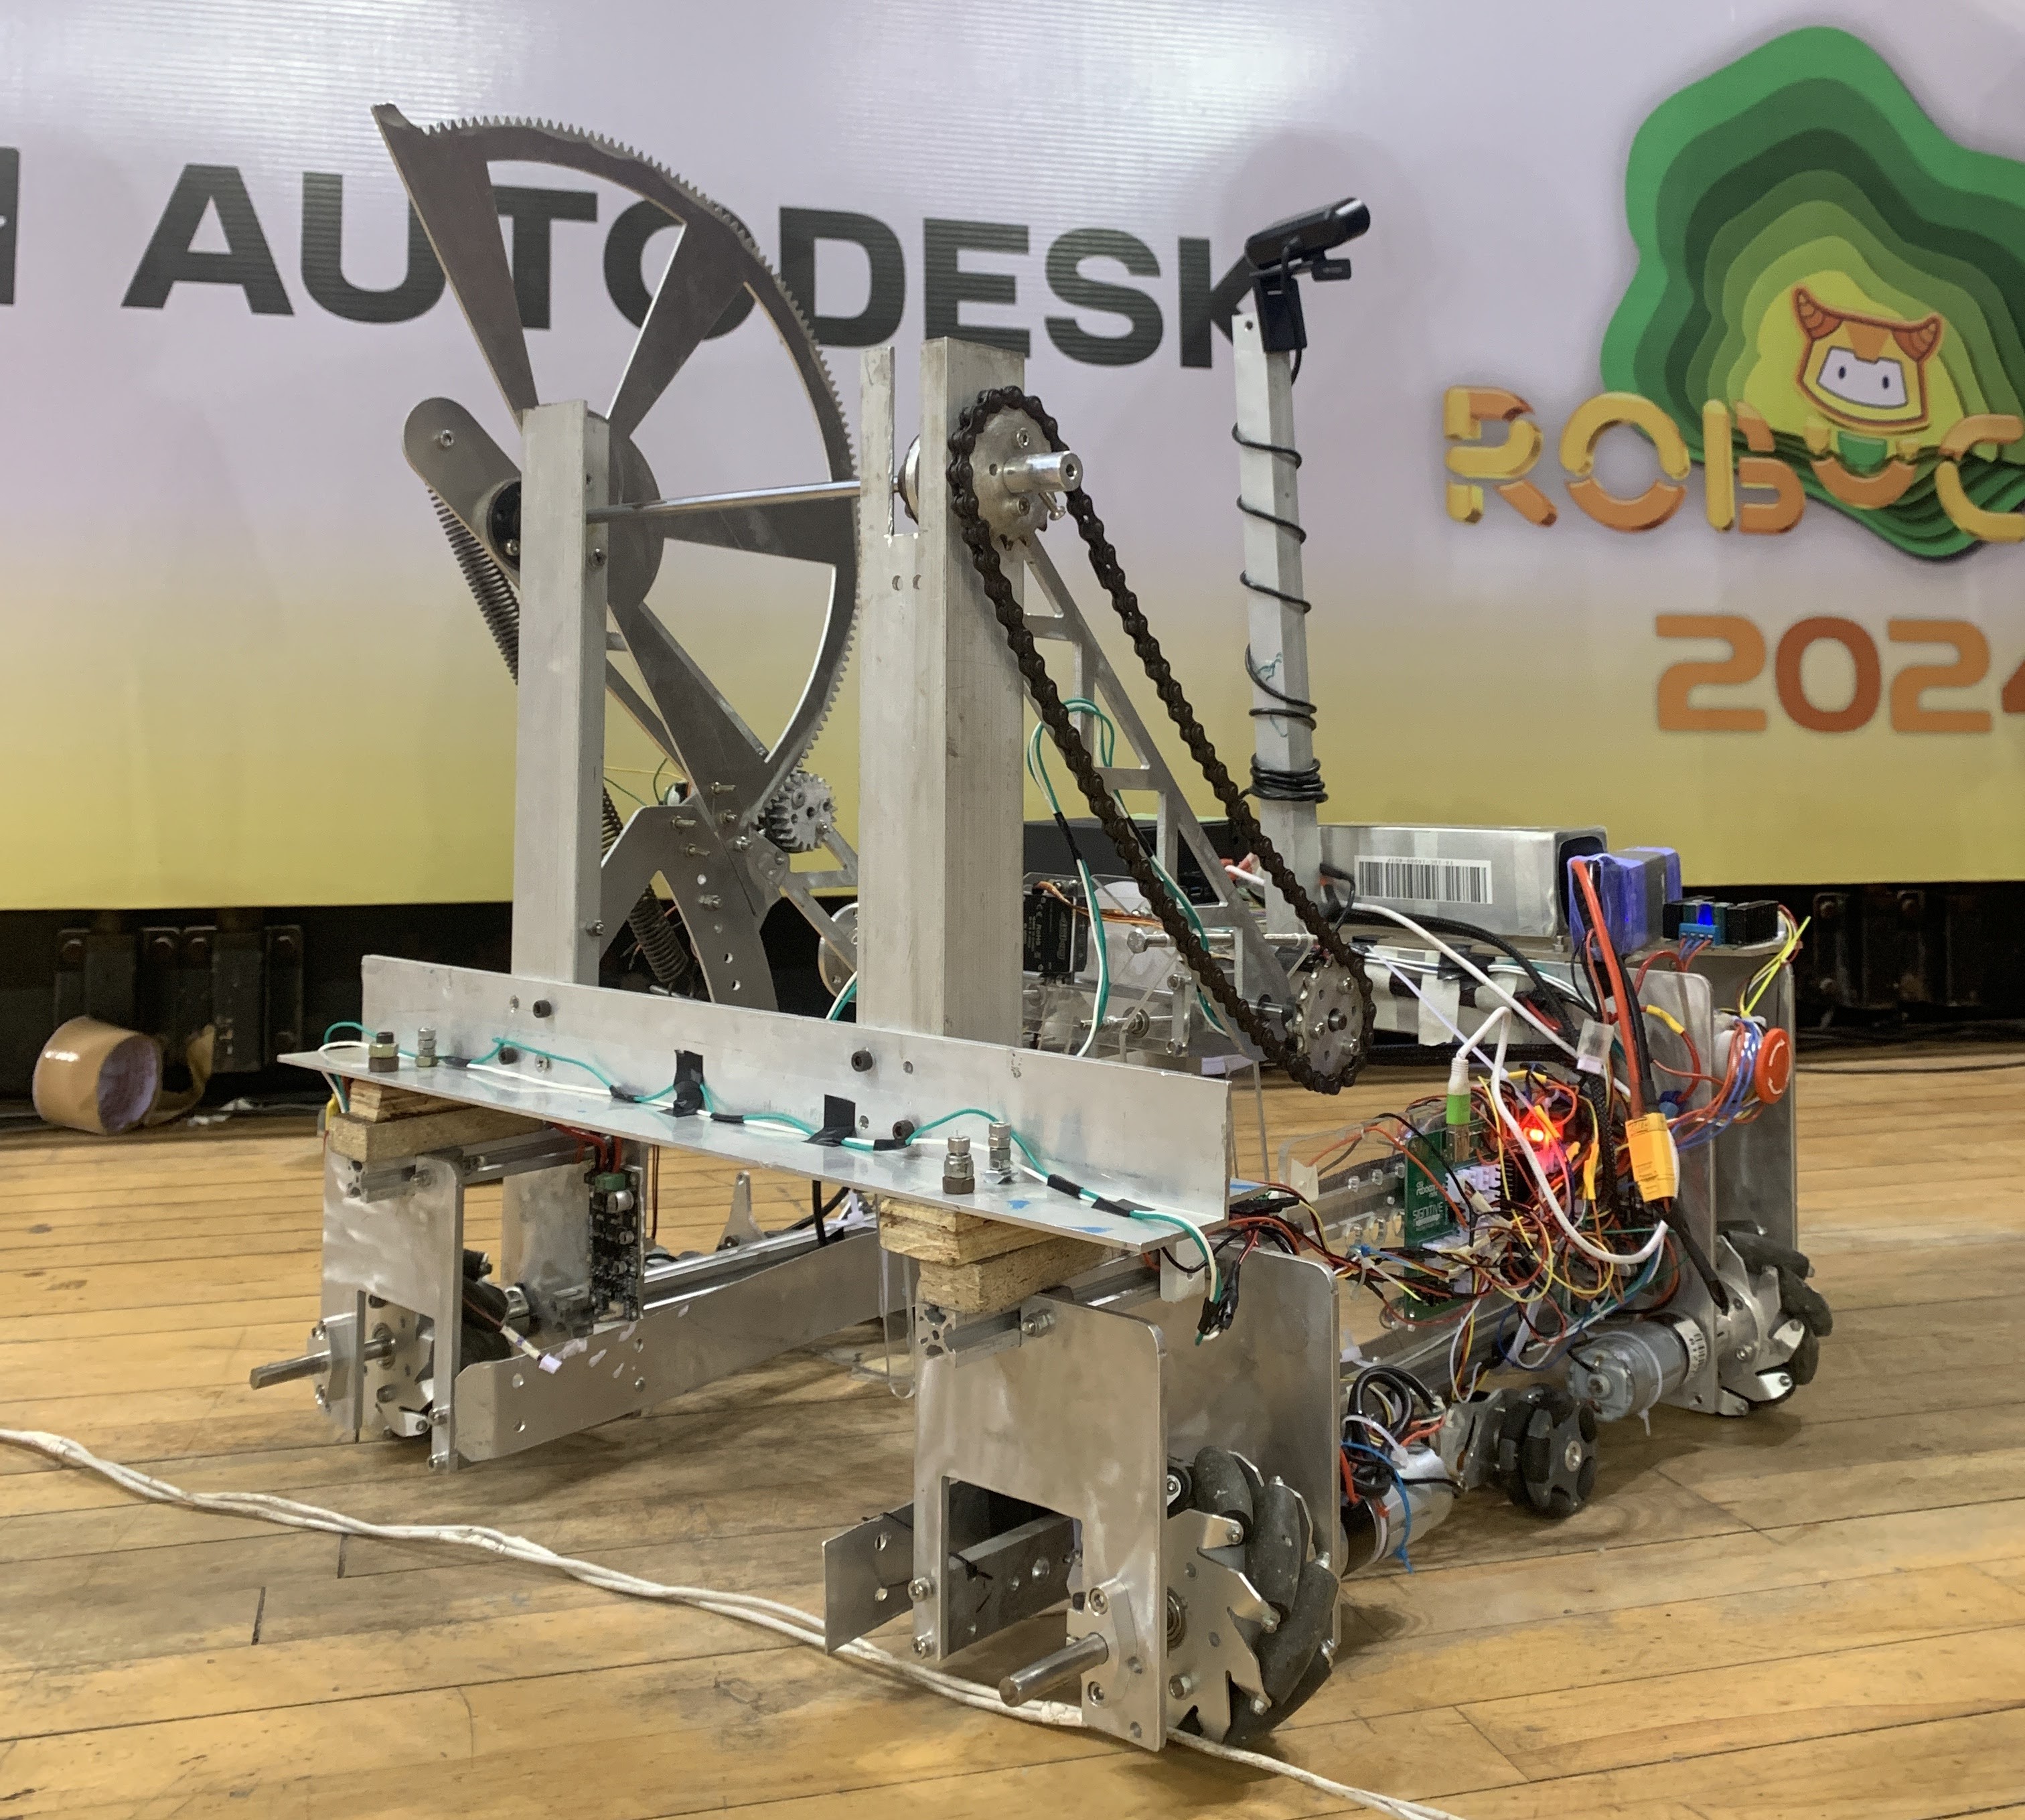
ABU Robocon 2024 asked for robots that could carry out a sequence of manipulation tasks entirely on their own. Leading a 32-person team, I drove the design and integration of two four-wheel holonomic robots that navigate, pick, kick, and sort — no human in the loop.
What I built
- Encoder-based navigation for repeatable waypoint following.
- Computer vision for colour-based object detection and sorting.
- Custom control algorithms binding perception to actuation across the task sequence.
Highlights
The project combined mechanical design in SolidWorks, custom PCB development in Altium, and in-house manufacturing — CNC machining, laser cutting, additive manufacturing, and PCB fabrication — to realise a genuinely end-to-end autonomous system. We qualified for the national round with a Robot Design Documentation score of 95/100.
Stack
SolidWorks · Altium · OpenCV · Python · C/C++ · CNC · laser cutting · PCB fabrication