Overview
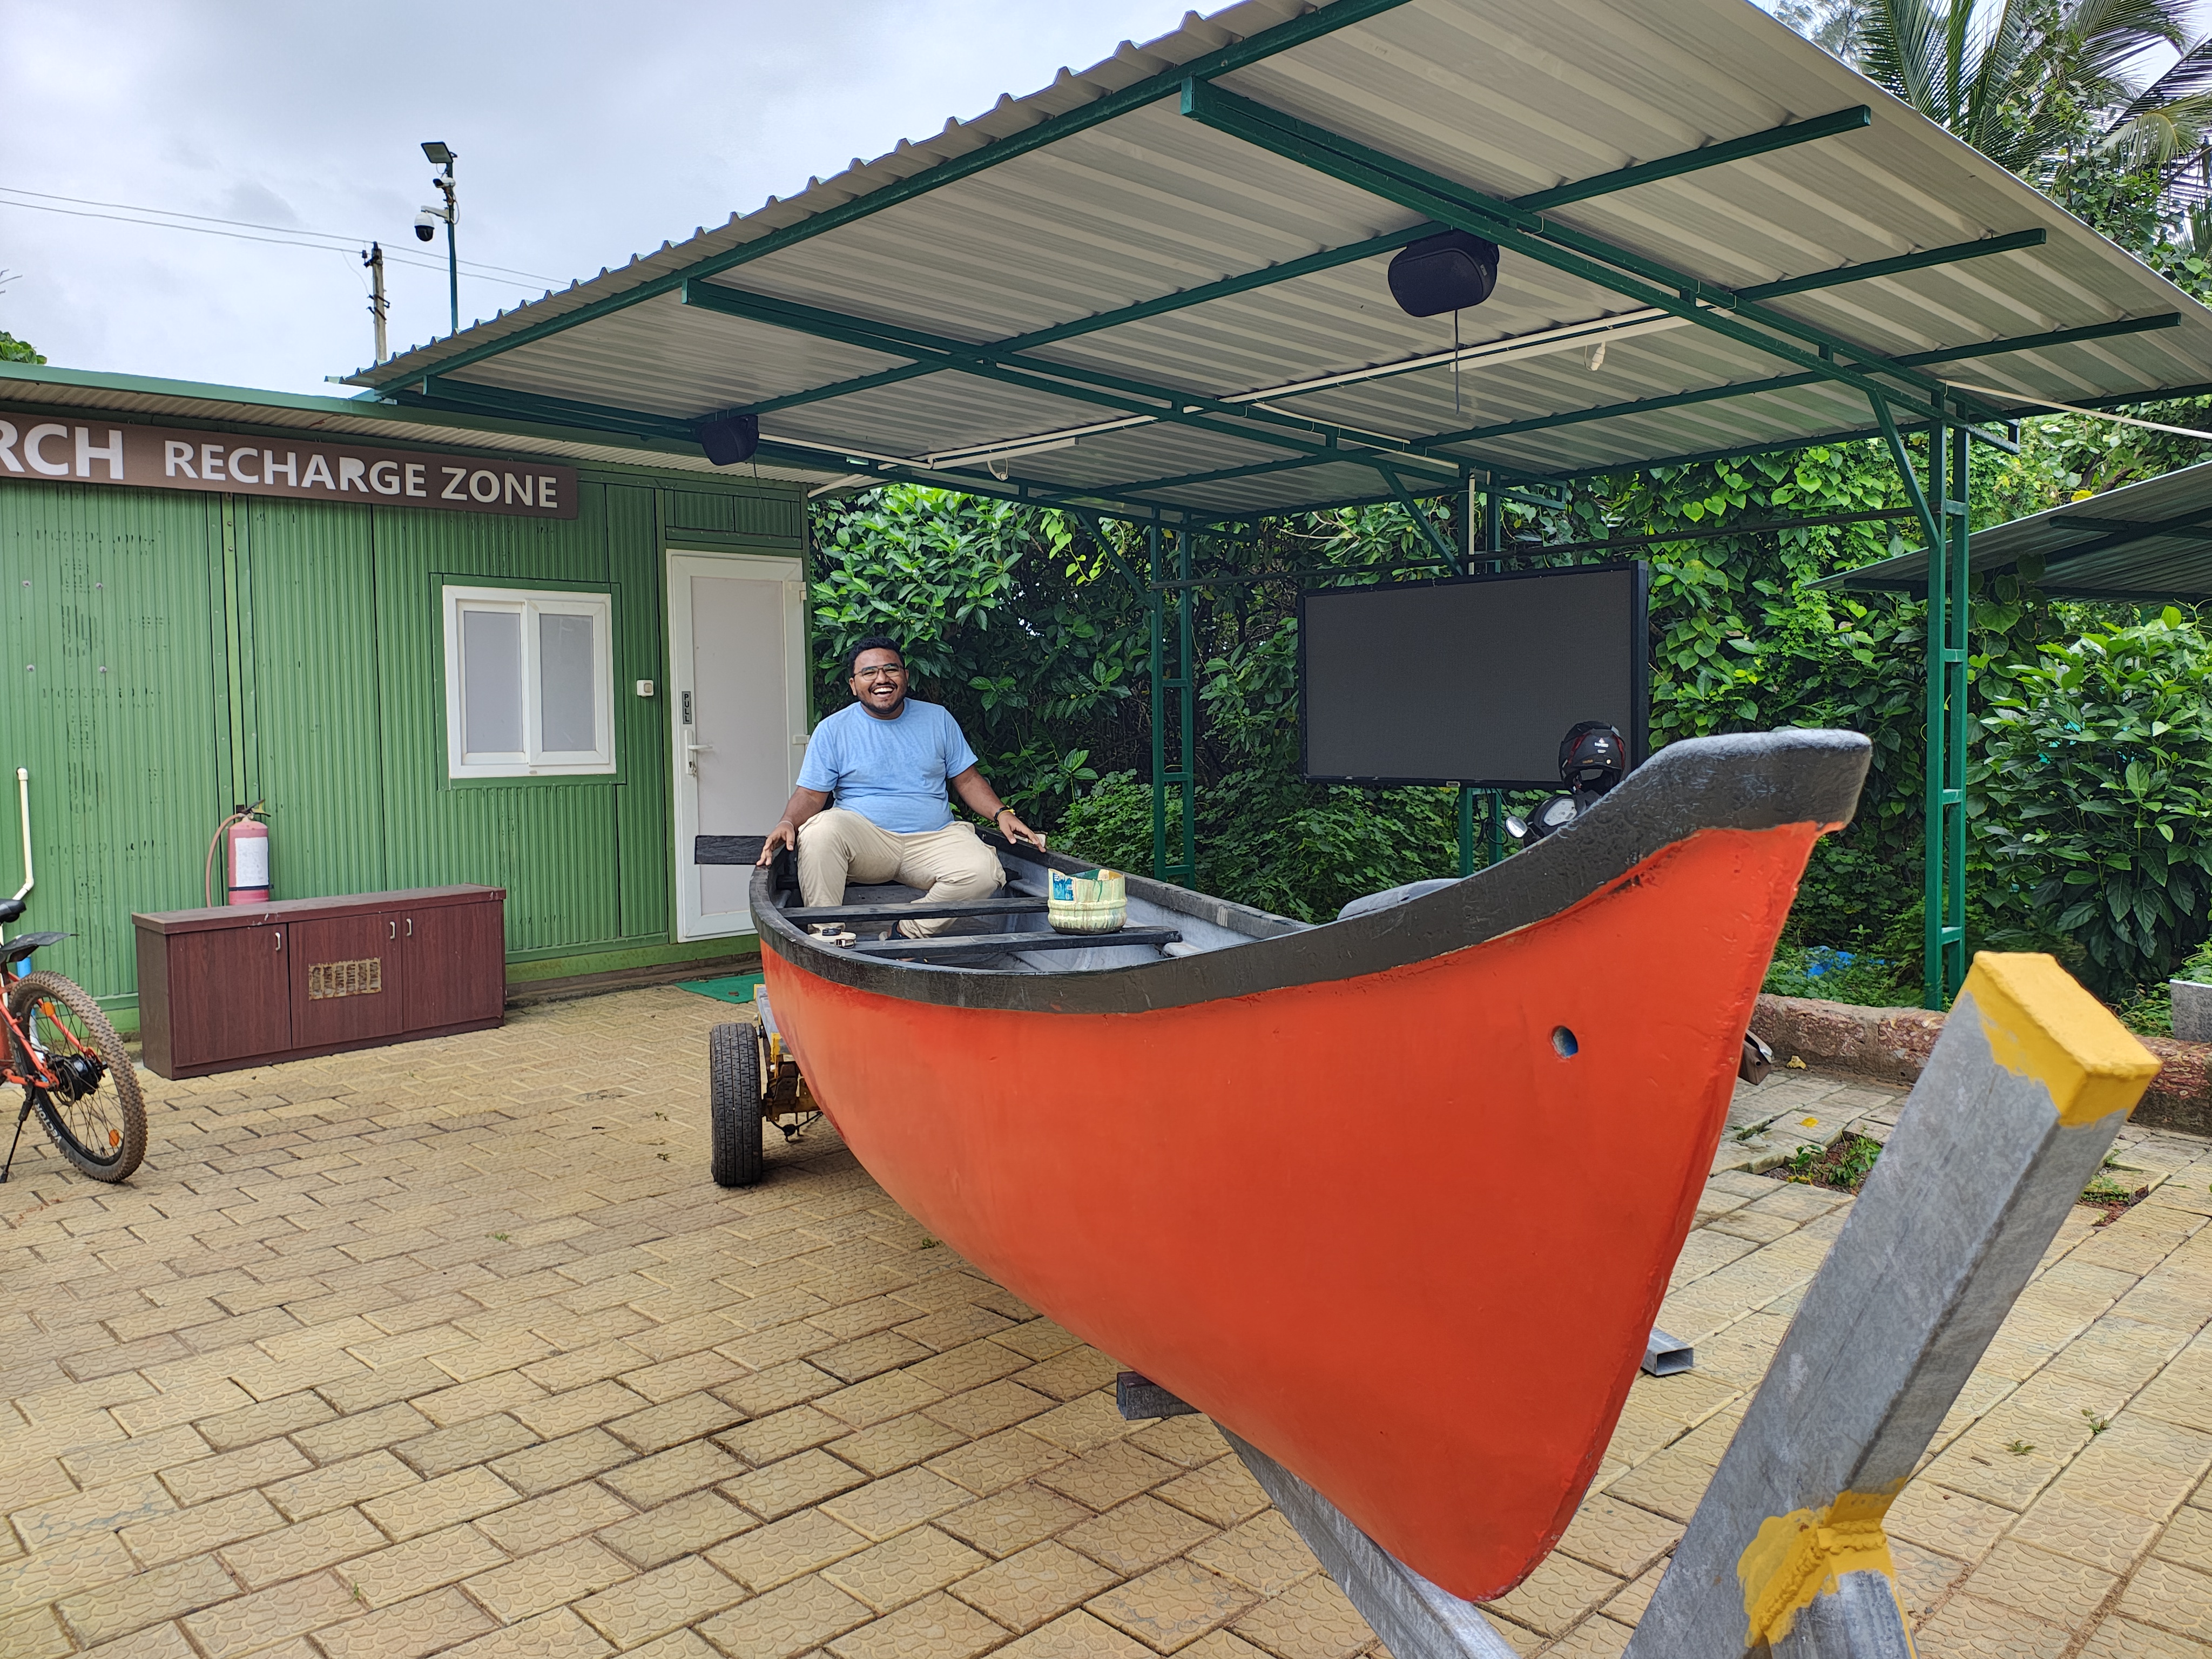
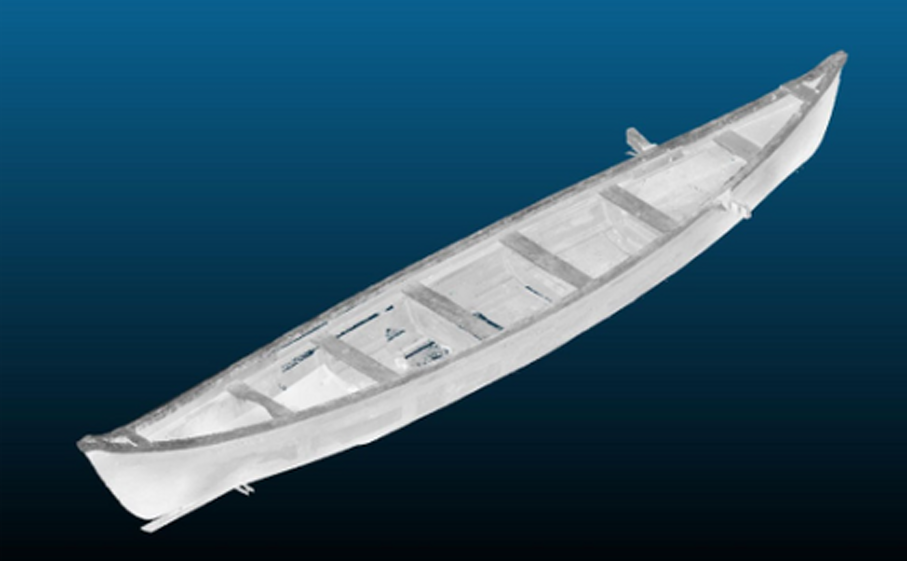
The Unmanned Surface Vessel project turns an ordinary fishing canoe into an autonomous platform for search-and-rescue operations and maritime surveillance. I was part of a five-person team covering the vessel, its trailer, its steering and drive, and the simulation used to test its control.
What I built
- A modified fishing canoe with an onboard compute module for autonomous navigation.
- A custom canoe trailer designed in SolidWorks, with half-ton capacity and an automated canoe-loading feature.
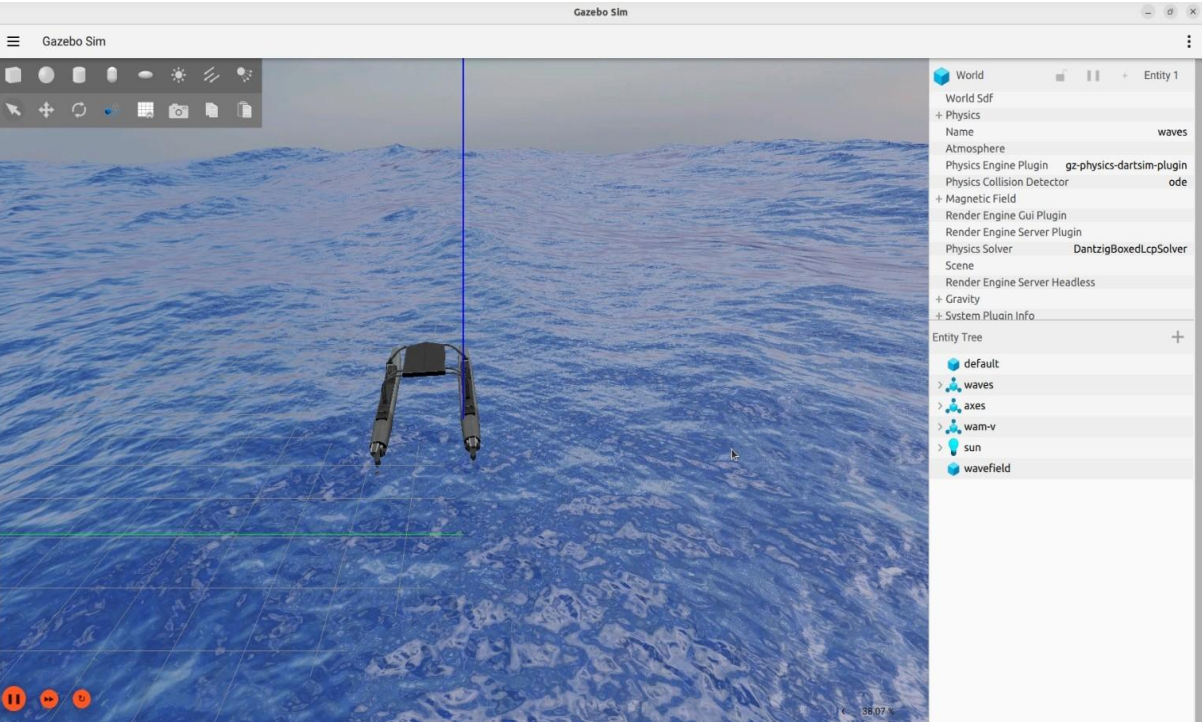
- A ROS–Gazebo simulation environment for testing control algorithms and autonomous navigation before touching the water.
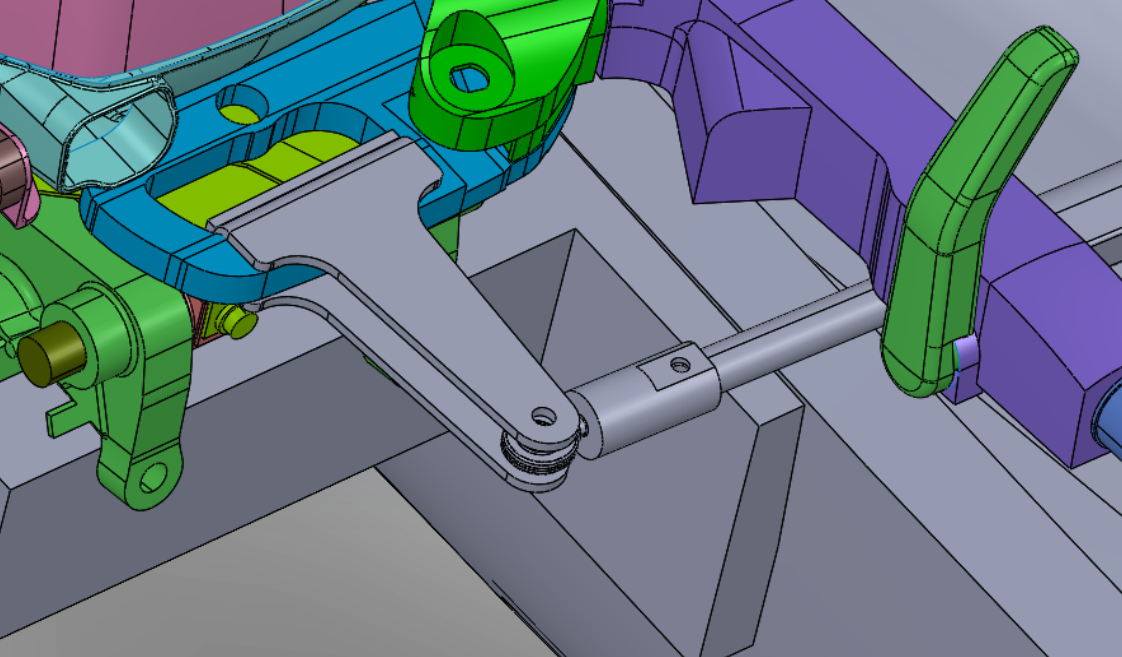
- The motor steering mechanism and the control system enabling RC operation, on a canoe powered by both a petrol and an electric motor for optimized performance.
Stack
ROS · Gazebo · SolidWorks · embedded control · petrol and electric propulsion